
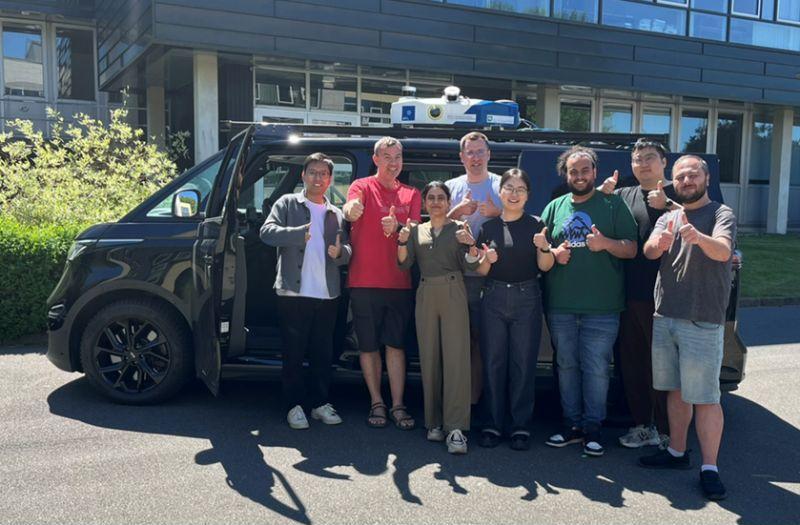
Clausi: Clausthal Autonomous Shuttle with Dependable Artificial Intelligence
Towards dependable and fail-operational automated driving
Clausi serves as a real-world research and testing platform for the development, integration, and evaluation of next-generation automated driving technologies.
Beyond supporting our research activities, the platform provides students, doctoral researchers, and research partners with opportunities to explore innovative AI-based driving functions, develop new system architectures, and validate their ideas in realistic driving environments.
Interested in shaping the automated driving of tomorrow?
Join our team and contribute to the development of safer, smarter, and more dependable autonomous mobility.
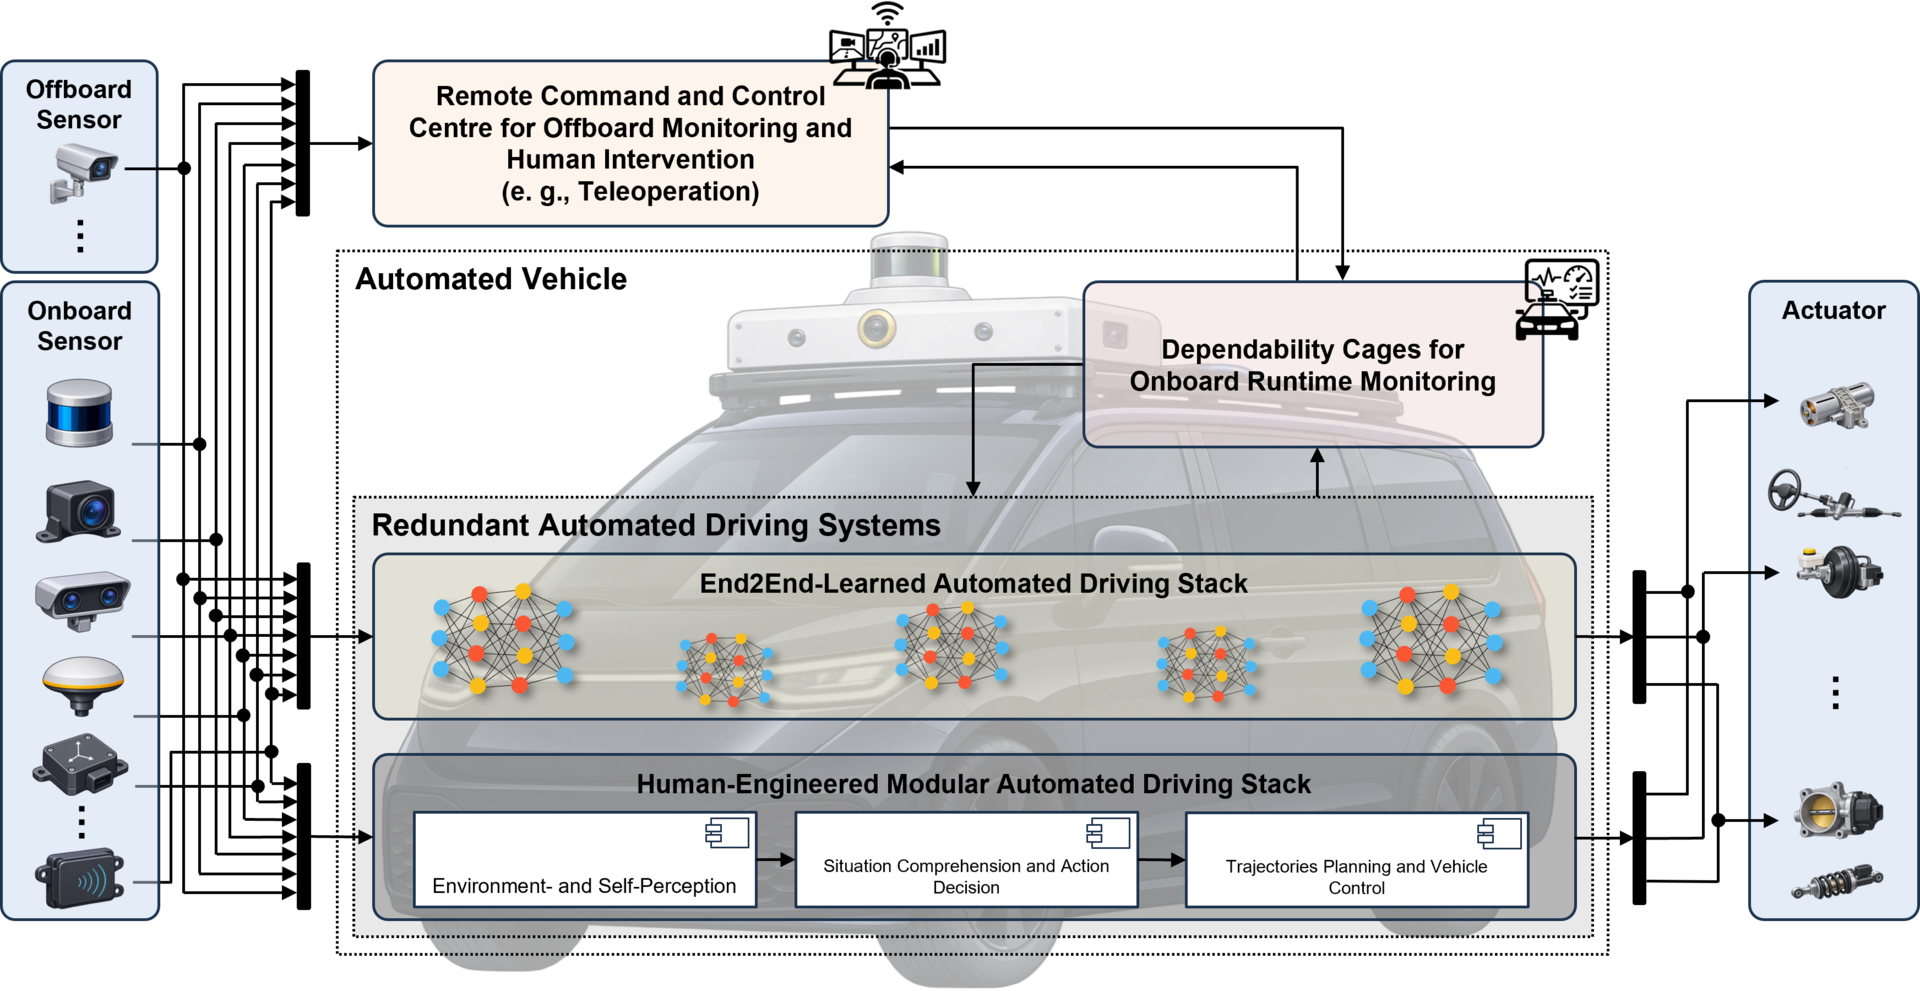
Our Overall Approach – Towards Dependable Automated Driving through Heterogeneous Redundancy and Continuous Engineering
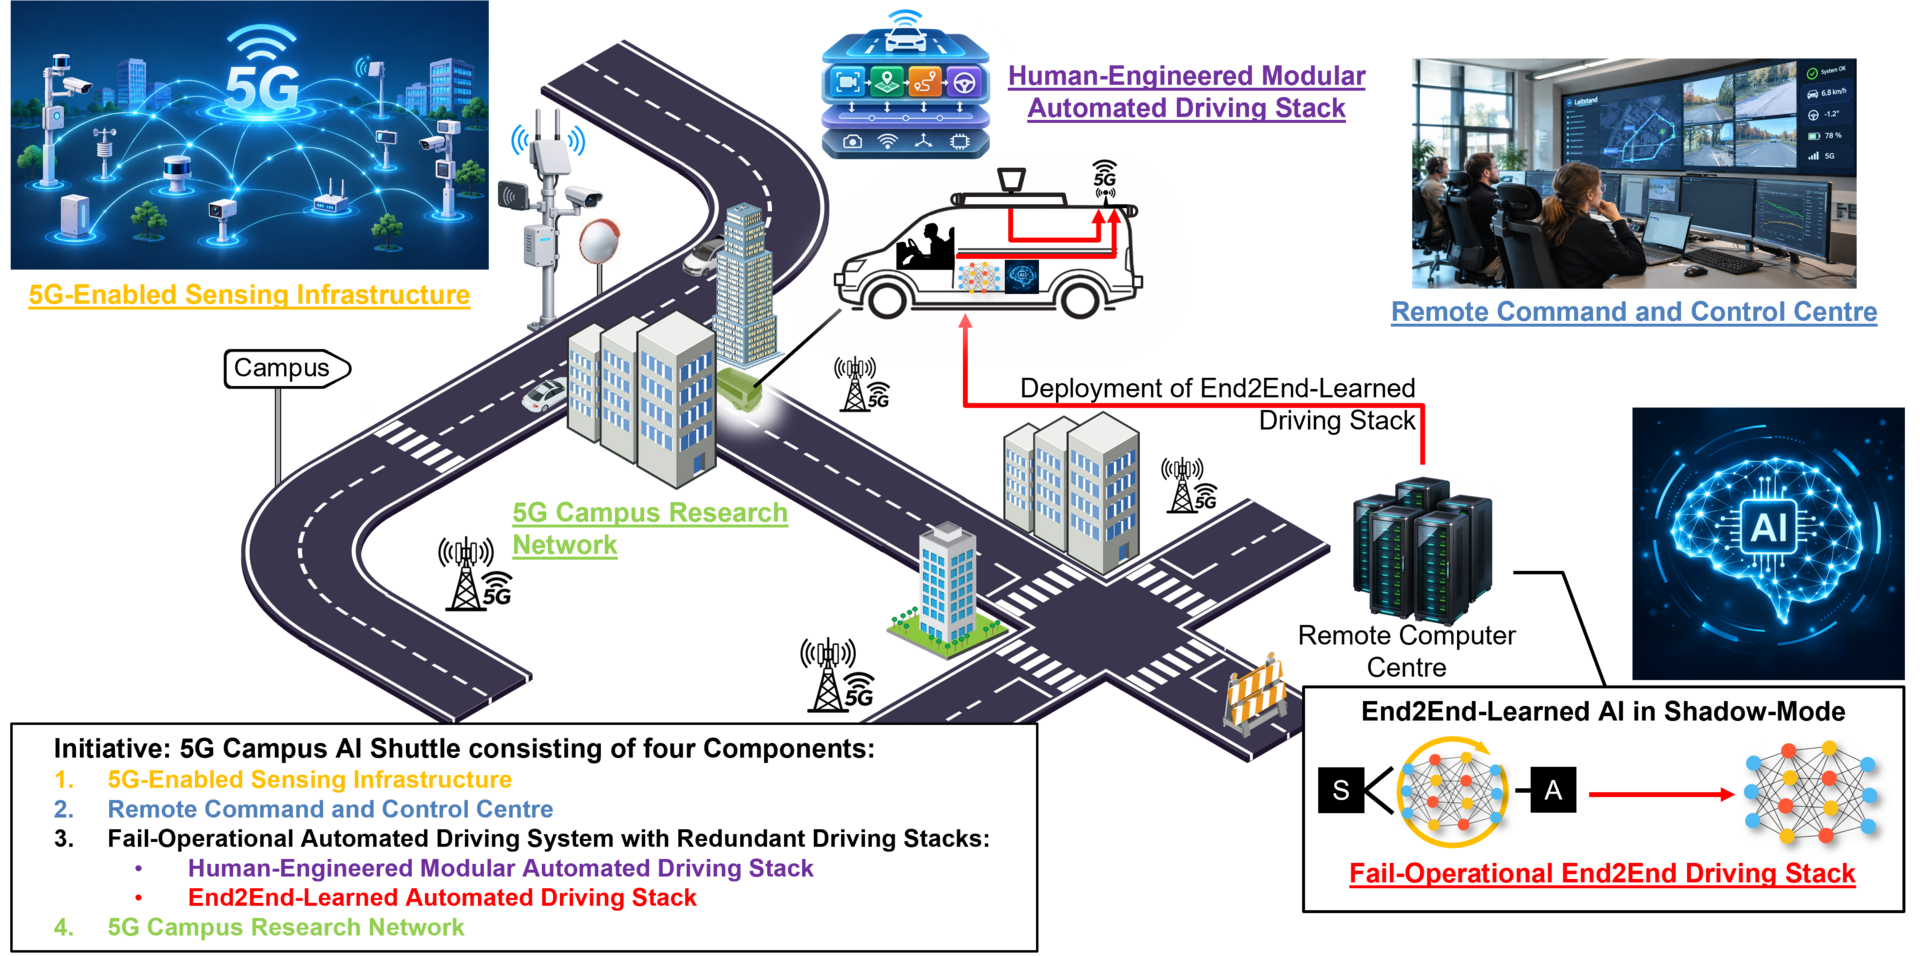
Our approach builds on a safety-oriented system architecture integrating multiple heterogeneous driving stacks, including a modular, human-engineered Autoware-based stack and an AI-based end-to-end driving stack. By providing complementary and redundant driving capabilities, this architecture aims to enhance fault tolerance and enable fail-operational behavior, allowing essential driving functions to be maintained under specified failure conditions.
At the core of our dependability framework, onboard Dependability Cages employ different types of monitors to continuously assess various aspects of system dependability. These include, for example, verifying compliance with defined functional, safety, and performance requirements, as well as detecting unknown or anomalous driving situations that have not been adequately considered during system engineering or represented in training data. When critical conditions or deviations are detected, the Dependability Cages can trigger appropriate safety measures, including switching between available driving stacks or initiating a safe fallback.
Complementing onboard monitoring, offboard monitoring through a remote command and control centre (German: Leitstand) enables centralized operational supervision and system-level analysis of a fleet of automated vehicles. When onboard monitors detect critical conditions or anomalies, they can notify the control centre, enabling human operators to assess the situation and intervene when necessary.
Beyond runtime safety assurance, Dependability Cages also contribute to continuous system engineering and improvement. Detected anomalies, critical situations, and relevant driving scenarios can trigger targeted data recording, providing valuable evidence for subsequent system analysis, validation, and iterative improvement, including the training and refinement of AI-based driving functions.
Together, heterogeneous driving architectures, onboard and offboard monitoring, and data-driven development establish a continuous engineering feedback loop, connecting real-world operation with the iterative development, validation, and improvement of dependable automated driving systems.
Our Vision – From Human-Engineered to AI-Enabled Automated Driving
Our long-term vision is to advance automated driving from predominantly human-engineered systems towards increasingly AI-enabled, end-to-end driving architectures, while maintaining the dependability required for SAE Level 4 and beyond.
We envision this transition as a gradual evolution. Initially, a human-engineered, modular automated driving stack provides the primary driving functionality, while an AI-based end-to-end stack is introduced as a complementary, redundant driving path. As AI capabilities mature and their performance and dependability are systematically validated, end-to-end driving functions can progressively assume greater responsibility within the overall system.
Throughout this evolution, Dependability Cages remain a central architectural element. They provide runtime supervision and safety assurance while identifying challenging scenarios, unexpected behaviors, and limitations of AI-based driving functions. These observations feed a continuous engineering process in which real-world data is analyzed, AI models are refined and retrained, and updated driving functions are validated before deployment.
By combining heterogeneous redundancy, runtime assurance, and continuous AI improvement, Clausi aims to explore a pathway towards fail-operational, AI-enabled automated driving systems capable of maintaining essential driving functions even in the presence of certain failures.
Research Highlights & Updates
Explore our recent achievements, research progress, and latest activities
R&D Initatives
Initiative 5: Camera-Lidar Fusion for Object-Aware Planning
Camera-lidar fusion lets CLAUSI detect and track vehicles, pedestrians and obstacles. Autoware uses these detections to stop, follow, wait for oncoming traffic and overtake parked cars; this is tested in 33 scenarios in the digital twin. The goal is to stop within ±2 m of the destination, three runs in a row.
Initiative 4: RTK-Accurate Localisation and Lidar-Fitted HD Map
Centimetre-accurate RTK positioning, a stable IMU heading, a calibrated sensor box and an HD map fitted to the real kerbs make CLAUSI drive consistently. The shuttle now travels repeatedly from Arnold-Sommerfeld-Straße to Leibnizstraße at up to 25 km/h, with automated tests in CI.
Initiative 3: Onboard Autoware Stack - First End-to-End Automated Drive
The complete Autoware stack runs on CLAUSI’s onboard computer. Using GNSS, IMU and lidar, the shuttle plans its own trajectory and drives itself to a destination picked on the map along Arnold-Sommerfeld-Straße.
Initiative 2: Autoware in the Loop - AWSim Digital Twin with GNSS Localisation
Our campus test route was rebuilt in the AWSim simulator, with CLAUSI’s vehicle model and sensors. There, Autoware drives the virtual shuttle from A to B using GNSS-only localisation, so every function can be tested safely before it goes on the road.
Initiave 1: Drive-by-Wire via ROS-CAN Vehicle Interface
CLAUSI’s steering, speed, doors, indicators and hazard lights are now controlled by software alone. A ROS–CAN interface on the onboard computer replaces the laptop and is operated from the rear-seat touch display.
Latest News
NOV 19, 2026
CLAUSI Advances Autonomous Driving with Improved Perception and Automated Testing
Our autonomous research shuttle CLAUSI continues to make progress toward more reliable and dependable autonomous driving.
A test case management system has now been integrated, and a Continuous Integration (CI) pipeline has been established to support systematic testing and validation throughout the development process.
In parallel, a LiDAR-camera fusion-based perception system has been prepared to improve the detection and understanding of the surrounding environment.
Furthermore, CLAUSI has been tested in the AWSim simulation environment, focusing on its ability to detect and react to dynamic objects, such as pedestrians and other vehicles.
These developments represent another important step toward more robust perception, systematic validation, and dependable autonomous driving.
NOV 04, 2026
CLAUSI Takes the Next Step Toward Reliable Autonomous Driving
Our autonomous research shuttle CLAUSI has achieved another important milestone: The vehicle successfully completed an autonomous drive from Arnold-Sommerfeld-Straße to a defined destination on Leibnizstraße on the TU Clausthal campus, with a maximum speed limit of 25 km/h.
Building on its first autonomous meters on campus, this achievement marks another significant step forward. Through targeted improvements to the HD map and extensive testing, consistent and reproducible driving behavior was demonstrated in both AWSim simulation and real-world vehicle tests. The autonomous drive was successfully repeated multiple times.
Another important step toward reliable autonomous driving!
OCT 23, 2026
From First Autonomous Meters to Stable Autonomous Driving
From the first autonomous meters to stable and precise autonomous driving! Following CLAUSI's initial autonomous driving demonstration, our team has achieved significant improvements in localization accuracy, digital map quality, and overall driving performance. By resolving key challenges in RTK-based localization and refining the Autoware configuration, CLAUSI now achieves stable, centimeter-accurate positioning and demonstrates smoother, more reliable autonomous driving on the TU Clausthal campus roads, including encounters with oncoming vehicles, pedestrians, and narrow road sections.
SEP 14, 2026
CLAUSI Drives Autonomously in the Real World for the First Time!
From zero to autonomous driving in just seven sprints! Within only 14 weeks, our team successfully transformed CLAUSI from a research vehicle platform into a shuttle capable of driving its first meters autonomously in a real-world environment.
Starting with basic vehicle communication and control interfaces, we progressively integrated the sensor systems, onboard computing infrastructure, mapping, localization, and the complete Autoware automated driving stack.
This achievement marks the successful completion of our first development phase and the beginning of systematic real-world testing and validation towards dependable, fail-operational autonomous driving.
AUG 04, 2026
Successful Autoware Simulation on Our Campus Test Route
Our autonomous research shuttle CLAUSI has reached another major milestone. The team has successfully integrated the Autoware simulation environment with CLAUSI's vehicle model, sensor configuration, and a digital map of our test route at TU Clausthal. With the complete Autoware stack now successfully running in simulation, the foundation is established for the next development phase: testing automated driving capabilities in the real-world environment.
JUL 02, 2026
Vehicle Control From Laptop to Onboard HPC
Our autonomous research shuttle CLAUSI has reached another important milestone. The Autoware Car Interface has been successfully deployed on the vehicle's onboard high-performance computing (HPC) platform, enabling manual control of steering, acceleration, and braking using either an Xbox controller or a keyboard connected to the onboard HPC.
This achievement marks a significant step towards integrating the complete autonomous driving stack into CLAUSI's onboard computing architecture, laying the foundation for future AI-based automated driving capabilities.
JUN 19, 2026
TUC.Autonomous.Buzz: First Successful Vehicle Control via Autoware Interface
Our TUC.Autonomous.Buzz now officially has a name: CLAUSI, representing our vision of a Clausthal Autonomous Shuttle with Dependable Artificial Intelligence.
Our autonomous research shuttle CLAUSI has reached another major milestone. Following the successful integration of auxiliary vehicle functions, the team has now demonstrated software-based control of steering, acceleration, and braking through the Autoware Car Interface. The next step is to migrate the control interface from the laptop-based setup to the vehicle's onboard high-performance computing (HPC) platform, laying the foundation for further integration of advanced AI-based automated driving capabilities.
JUN 10, 2026
TUC.Autonomous.Buzz: First Successful Control of Auxiliary Vehicle Functions via Autoware Interface
Our TUC.Autonomous.Buzz has reached its first software integration milestone. By implementing an initial Autoware Car Interface and connecting it to the vehicle's CAN interface, the team successfully demonstrated software-based control of turn indicators, hazard warning lights, door opening, and other vehicle auxiliary functions.
May 31, 2026
Sensor and Computing Infrastructure Integration
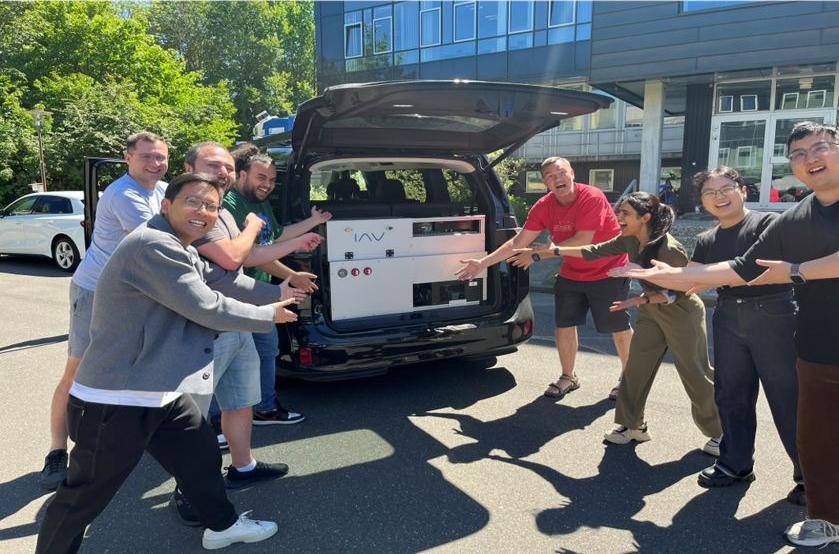
Another milestone for TUC.Autonomous.Buzz: The roof-mounted sensor system and NVIDIA-powered high-performance computing infrastructure have been installed. With the core hardware in place, the project is moving into software integration and the first functional tests on the path towards dependable autonomous driving.
MAY 19, 2026
Vehicle Preparation and Safety Training
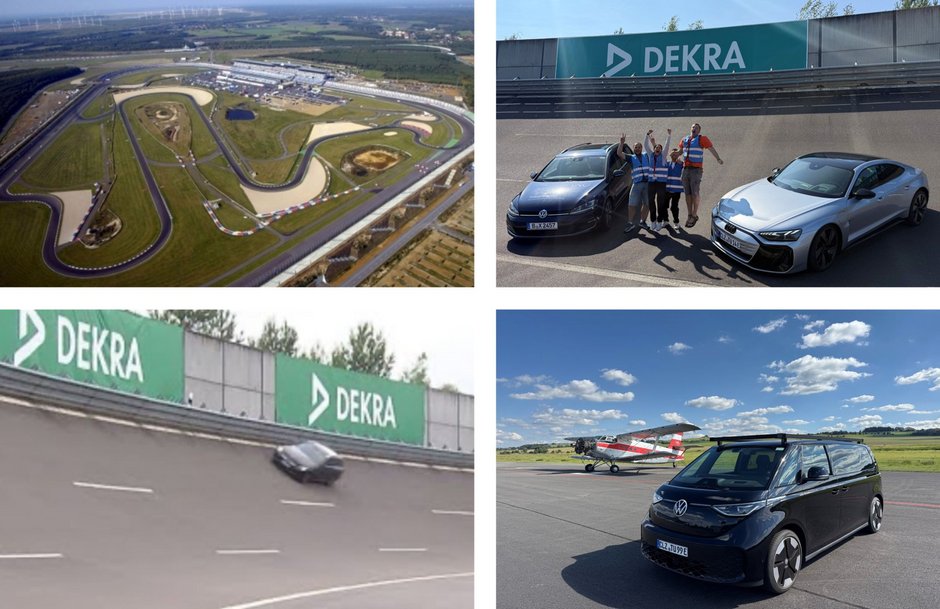
Our ID.TUC.Buzz research vehicle has been prepared for autonomous driving. Following specialized safety training at the Lausitzring, the next development phase will focus on integrating AI-based driving functions, sensor systems, and safety mechanisms for dependable, fail-operational automated driving.